When designing a motion control system, many engineers focus solely on torque and speed. However, the most frequent cause of "tuning frustration" and system instability is an Inertia Mismatch.
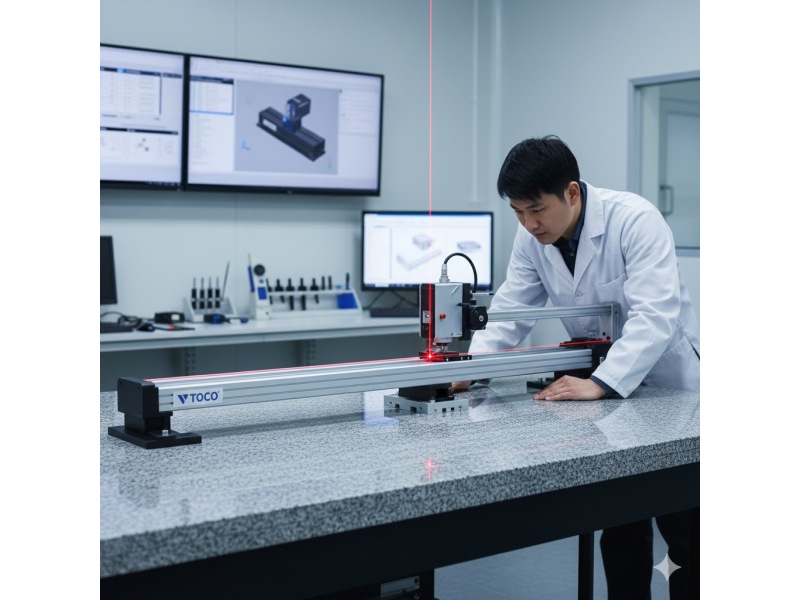
If your TOCO linear stage vibrates at the end of a move or feels "spongy" during acceleration, you likely have an inertia problem.
What is Inertia Ratio?
The inertia ratio is the relationship between the Load Inertia (the resistance of the moving parts and the payload to a change in speed) and the Motor Inertia (the internal resistance of the motor's rotor).
Ratio = Jload/Jmotor
For a high-performance system, a ratio of 1:1 is ideal, but for most industrial applications using TOCO ball screw stages, a ratio of 5:1 or 10:1 is perfectly acceptable. Once you exceed 20:1, the motor loses "authority" over the load, leading to resonance.

Why High Ratios Kill Performance
Resonance and Noise: The motor's encoder sees the load "wagging the dog," causing high-frequency oscillations.
Longer Settling Times: The system takes longer to come to a complete stop at the target position, slowing down your cycle time.
Drive Overheating: The servo drive works overtime trying to correct for the mismatch, generating unnecessary heat.
How to Optimize Inertia for TOCO Stages
If your calculation shows a mismatch, you have three engineering "levers" to pull:
1. Change the Ball Screw Lead
The ball screw lead has a squared effect on reflected inertia. Reducing the lead (e.g., from 20mm to 10mm) significantly reduces the inertia the motor "feels."

2. Add a Gearbox
A planetary gearbox reduces the reflected inertia by the square of the gear ratio. A 5:1 gearbox reduces the load inertia by a factor of 25.
3. Increase Motor Size
Sometimes, the simplest solution is choosing a motor with a larger rotor (higher internal inertia) to "balance the scales" against a heavy TOCO carriage and payload.
Conclusion
A balanced system is a quiet system. By calculating your inertia ratio during the design phase of your TOCO motion project, you ensure that your servo tuning is effortless and your machine throughput is maximized.


 English
 German
 French
 Russian
 Spanish
 Japanese
 Korean
 Khmer
 Portuguese
 Ukrainian
 Arabic
 Italian
 Afrikaans
 Albanian
 Armenian
 Azerbaijani
 Basque
 Belarusian
 Bulgarian
 Catalan
 Croatian
 Czech
 Danish
 Dutch
 Estonian
 Filipino
 Finnish
 Galician
 Georgian
 Greek
 Haitian Creole
 Hebrew
 Hindi
 Hungarian
 Icelandic
 Indonesian
 Irish
 Latvian
 Lithuanian
 Macedonian
 Malay
 Maltese
 Norwegian
 Persian
 Polish
 Romanian
 Serbian
 Slovak
 Slovenian
 Swahili
 Swedish
 Thai
 Turkish
 Urdu
 Vietnamese
 Welsh
 Yiddish